- Sep 2026: 📝 Submitted a first-author paper on learned Tube-MPC for gimbal pointing to IEEE TCAS-II.
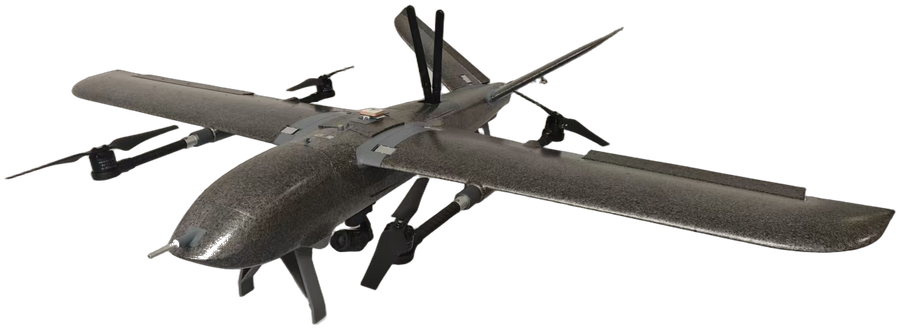
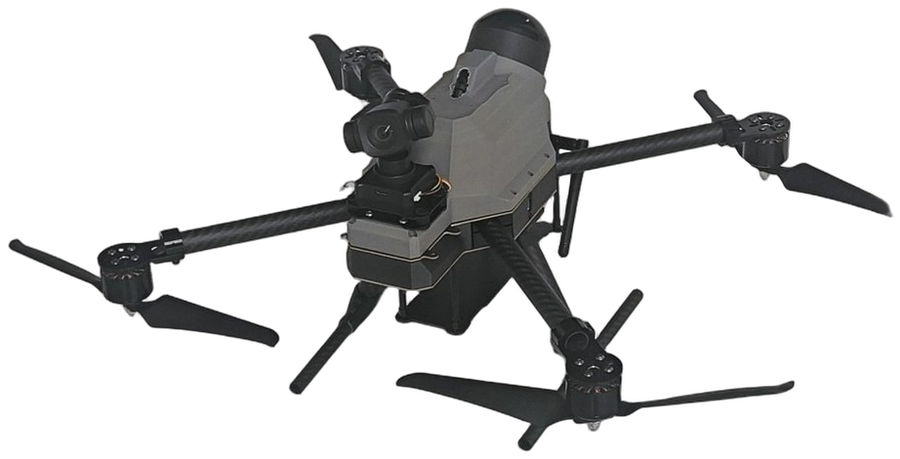
- Sep 2026: 🛩️ Built a compound-wing (quad-plane) VTOL with a belly-mounted gimbal pod for flight tests of joint aircraft–gimbal planning.
- Jul 2026: 🌉 Joined the Jiangsu Communications Holding bridge-inspection challenge track (team led by Prof. Jianzhong Qiao). I work on onboard system integration, coverage-planning simulation and under-bridge flight tests.
- Jun 2026: 🎤 Gave an oral presentation at IEEE ICCA 2026 in Almaty, Kazakhstan; the first-author paper is in the proceedings (DOI).
- Jun 2026: 🎓 Passed my Ph.D. thesis proposal defense.
- May 2026: 📝 Submitted a first-author paper on disturbance-separation MPC to IEEE TAES.
- 2026: 📄 Co-authored paper published in Actuators (DOI).
- Nov 2025: 📑 Patent application accepted on coupled gimbal-frame dynamics modeling for airborne electro-optical tracking on a moving base (CN 202511693696.5).
- 2025: 📄 Co-authored paper published in IEEE/ASME Transactions on Mechatronics (DOI).
- Aug 2024: 📄 Co-authored paper at ICGNC 2024, Changsha.
- Sep 2023: 🚀 Started my Ph.D. at Beihang University.
Hello, I'm Yaokun Lu (卢耀坤)
I am a Ph.D. student at the School of Automation Science and Electrical Engineering, Beihang University (BUAA), advised by Prof. Lei Guo (Academician, CAS) and Prof. Jianzhong Qiao. I received my M.S. (2019) and B.S. (2016) from the University of Electronic Science and Technology of China (UESTC).
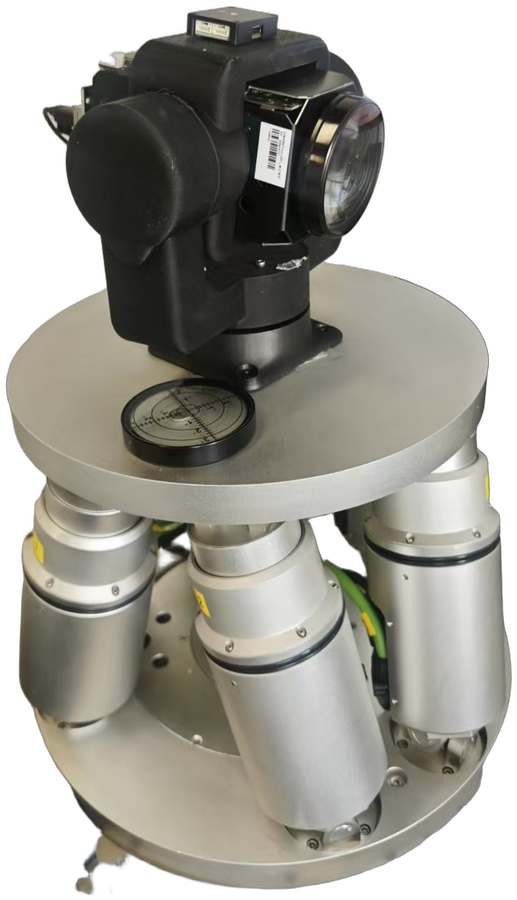
My research is on precise pointing of airborne electro-optical systems under disturbances and constraints: multi-stage (aircraft, gimbal, fast-steering mirror) line-of-sight control with learning-based Tube-MPC and disturbance separation, validated on a two-axis gimbal testbed I built. I also work on joint aircraft–gimbal coverage planning for fixed-wing UAVs in non-uniform wind.
Before my Ph.D., I was a senior algorithm engineer at DiDi Chuxing for three years (ETA prediction, passenger diversion and online dispatch models), a research assistant with Prof. Fei Gao at Zhejiang University’s Huzhou Institute for a year, and a flight-control intern at DJI. I founded a UAV company during my master’s study. I will graduate in June 2027 and am open to full-time positions from July 2027.